North South University
B.Sc. in Electrical & Electronic Engineering
Robotics & Intelligent Systems
Drone Swarms · CubeSat Radio · CFD
EEE graduate from North South University and research assistant at NIRO Lab. I work on multi-drone flight, from simulation to real hardware, and on the radio links of a 3U CubeSat.
I studied Electrical & Electronic Engineering at North South University, with a specialization in robotics. Most of my work is on drones that fly together: formation control and collision avoidance in CoppeliaSim first, then the same code on Pixhawk quadcopters outdoors. I also work on the radio side of NSU-AI-SAT, a 3U CubeSat, and run CFD for the lab's ring-wing VTOL airframes. What survives the move from simulation to real hardware is what interests me most.
B.Sc. in Electrical & Electronic Engineering
Research Assistant · NIRO Lab
NSU Intelligent Robotics Lab, North South University · May 2026 – present
Student Researcher, Summer 2025 – Apr 2026
Advised by Dr. Shahnewaz Siddique, Lab Director. I work on the lab's 3-drone swarm, co-designed the frequency plan for the NSU-AI-SAT CubeSat and built its GNU Radio signal chains, and run CFD on the lab's ring-wing VTOL airframes.
Multi-agent aerial robotics, swarm coordination, formation control, and autonomous mission execution.
Physics-based modeling and simulation of aerial vehicles: vehicle dynamics, flight control and aerodynamics.
Project 01
Precision Agriculture · Fisheries · Drone Shows
A 3-drone swarm I built with a four-person team, first in CoppeliaSim and then on Pixhawk 2.4.8 quadcopters. The first outdoor 3-drone formation flew in March 2026. In field tests, positioning error fell from 9–10 m with M6 GPS to 0.5–1 m with M9N modules and an RTK base station. In a simulated light show the drones never came within 2.2 m of each other. Built for spraying or feed dispensing; flight tests used LED payloads.
Code is private until the work is published.
Project 02
3U CubeSat · APSCO CubeSat Competition
On the communications team, I co-designed the five-mode UHF/VHF/S-band frequency plan and built the GNU Radio signal chains for the satellite and the ground station, checking QPSK modulation, carrier and timing recovery, and S-band burst timing. Under the team's link budget, the 1 Mbps S-band downlink closes with 16.5 dB of margin at 24° elevation and sends a full 156 Mbit observation in one pass.
Project 03
Ring-wing VTOL airframe CFD
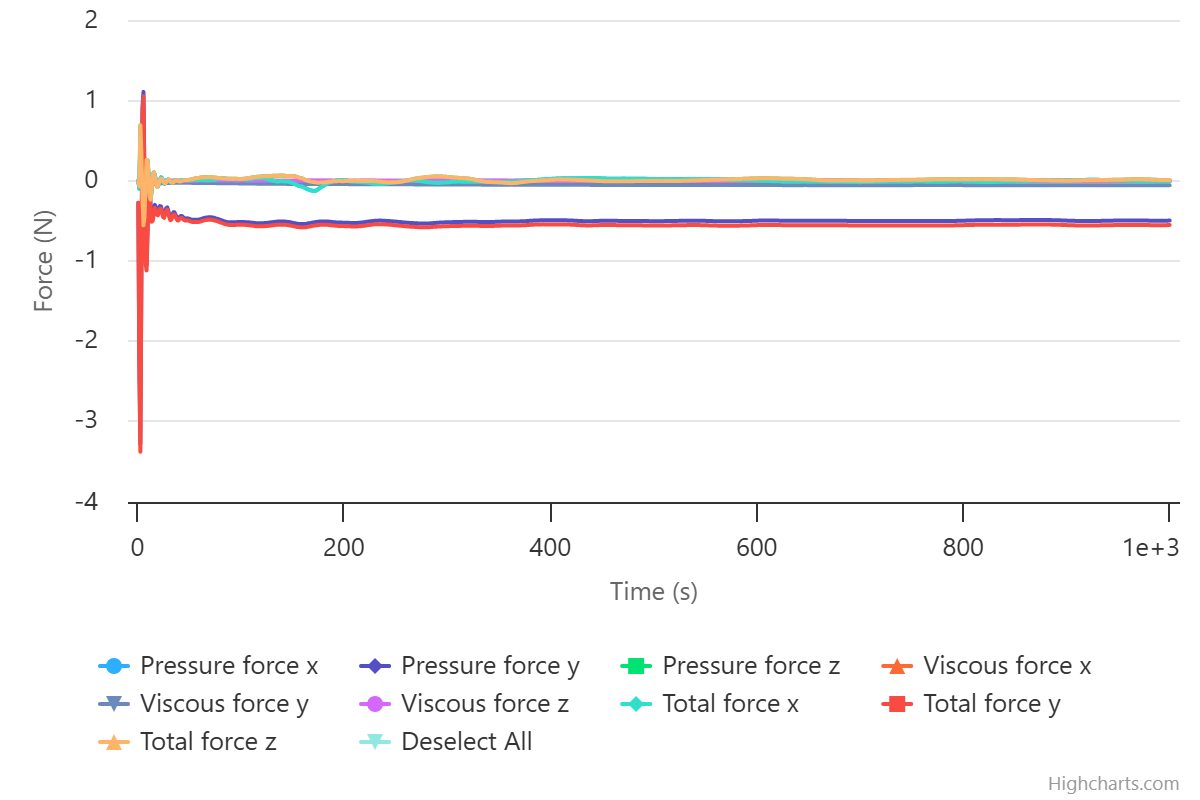
I ran SimScale CFD on two ring-wing airframes designed by the lab's project lead. At 15 m/s the smaller MK3 had 19% less drag than MK2 (0.55 N vs 0.68 N), but its drag coefficient was slightly higher (0.156 vs 0.145), so most of the gain came from size, not shape.
Project 04
PyTorch · trained from scratch
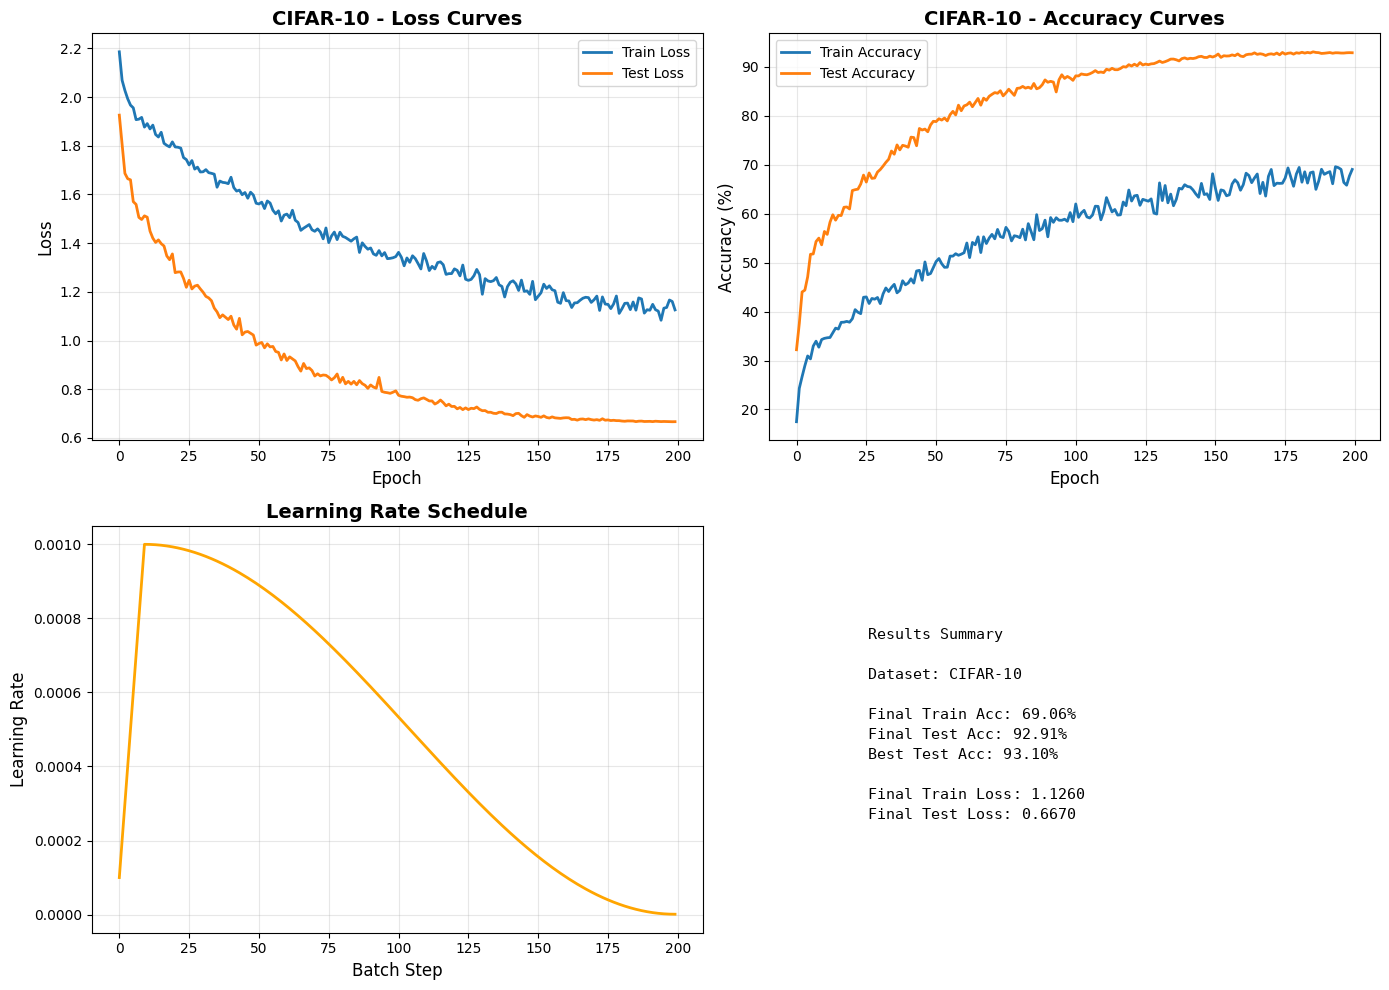
A Vision Transformer with a convolutional stem, written from scratch in PyTorch. It reaches 92.9% test accuracy on CIFAR-10 and 74.7% on CIFAR-100 after 200 epochs. A hyperparameter comparison showed that pushing the learning rate to 3e-3 made training diverge.
Python · C/C++ (embedded) · PyTorch
ArduPilot · PX4/Pixhawk · MAVLink · Mission Planner · PID & cascaded control · Formation control · Collision avoidance · Trajectory planning
GNU Radio · Software-defined radio · RF frequency planning · CubeSat communications
STM32 · Raspberry Pi · RTK GPS · Sensor integration
CoppeliaSim · SimScale (CFD) · MATLAB & Simulink